01
IRI (CSIC–UPC)
Student Researcher
Developing path-conditioned diffusion policies for SOLO12 quadruped locomotion, using hindsight relabeling over pretrained walking and crouching policies, with DPPO fine-tuning in Isaac Lab.
Hi, I’m Sergi Flores.
Final-year AI student at UPC, currently on exchange at NTUST in Taiwan. I’m mainly interested in robotics and computer vision, especially where learning, perception and control meet.
01 / experience.log
IRI (CSIC–UPC)
Developing path-conditioned diffusion policies for SOLO12 quadruped locomotion, using hindsight relabeling over pretrained walking and crouching policies, with DPPO fine-tuning in Isaac Lab.
MANGO
Worked on diffusion-based image generation and virtual try-on, fashion landmark detection, and end-to-end computer vision pipelines for fashion applications.
02 / education.md
NTUST · Taiwan Tech
UPC · Facultat d’Informàtica de Barcelona
03 / projects.json
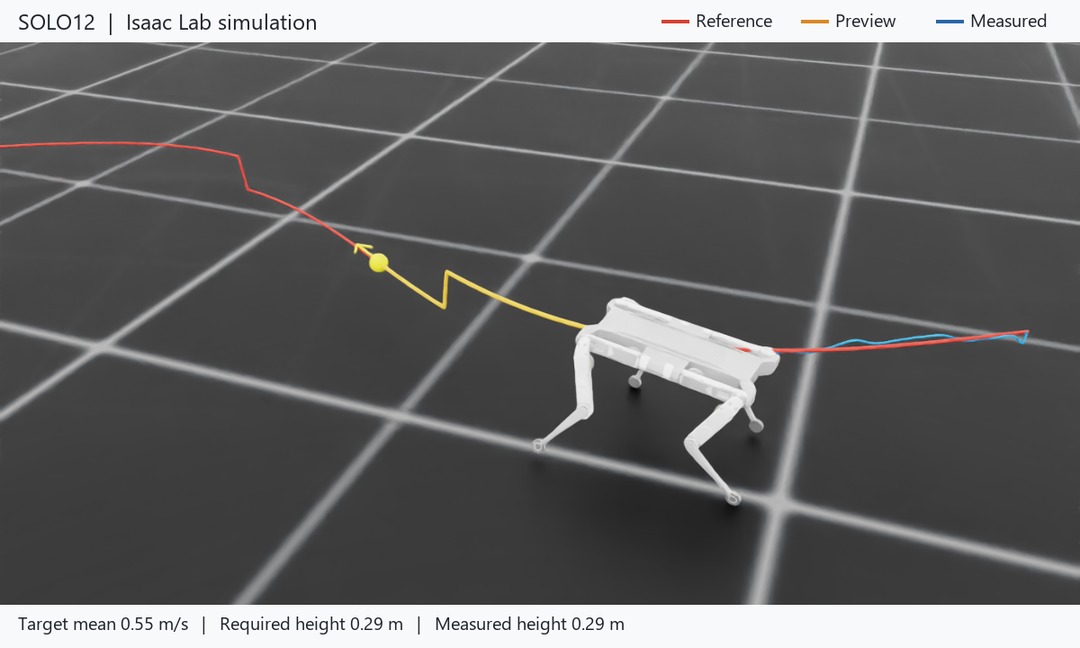
Research project on path-conditioned diffusion policies for SOLO12 quadruped locomotion, using hindsight relabeling over pretrained walking and crouching policies, with DPPO fine-tuning.

The complete ROS 2 stack for an autonomous competition rover: RGB-D perception, localization, navigation and sample collection.
A real-world multi-robot Capture the Flag system for TurtleBot3 Waffle Pi, combining collaborative SLAM, global and local path planning, computer vision, and autonomous coordination.

A task and motion planning system for solving a physical 2×2 Rubik’s Cube with a UR3 robot, PDDL and OMPL/Kautham planning.

High-precision trajectory tracking for the Universal Robots UR3 using Soft Actor-Critic (SAC) reinforcement learning in MuJoCo, featuring curriculum learning and reward shaping strategies.
DDPM-based generative model for CMS low-level collision data. Compares diffusion models against GANs and VAEs using statistical metrics (MMD, 1-NN, correlation gap), showing improved fidelity on sparse physics distributions.
Set of experiments on equivariant vision models for image and sequential data using FITS astronomical inputs. Includes training, evaluation, and visualization pipelines for both general and sequential workflows.
A computer-vision pipeline that turns handheld video into a semantic 3D representation.
Reinforcement learning repository covering discrete model-free algorithms (Monte Carlo, SARSA, Q-learning) and continuous-control actor-critic methods (DDPG, TD3)
Our team developed a computer vision–powered web application that enables users to explore high-resolution stellar images through natural language queries.
Semi-supervised continuum scoring for medulloblastoma subtype classification, winner of the BSC challenge at BITS x La Marató 2025.
Real-time human detection, tracking and 3D pose reconstruction from multiple camera streams, awarded second prize at HackEPS 2025.
A multimodal RAG assistant, vehicle-part detector and 3D viewer built for the CUPRA challenge at HackUPC 2025.
Street-level air-quality forecasting across Catalonia with spatial interpolation, traffic data, Random Forest and LightGBM.
End-to-end system for participant matching using feature engineering, PCA-based clustering, and cosine similarity. Groups users into balanced teams while considering prior connections and preferences, supported by a web interface and an AI chatbot for explainability and interaction.
04 / awards.csv

SENER–CEA Bot Talent · Barrendeiros
After six months developing and integrating an autonomous ROS 2 rover, Team Barrendeiros represented UPC at the final in Madrid. The system received the competition’s Technology and Design awards.
view project ↗
BITS x La Marató · BSC Challenge
We won the BSC challenge at Bits x La Marató, a charity hackathon supporting La Marató de TV3, with a semi-supervised continuum-scoring approach for medulloblastoma subtypes.
view project ↗
HackEPS · INGROUP Challenge
We received second prize for a real-time 3D motion-capture system built from two IP cameras, stereo triangulation and YOLOv8-Pose.
view project ↗
NASA Space Apps Challenge
AI i Oli was one of two global nominees at the Barcelona edition. It combines classical computer vision with natural-language-to-SQL queries for exploring stellar images.
view project ↗
HackUPC · CUPRA / SEAT Challenge
CARmen received second prize for turning the CUPRA Tavascan manual into an interactive platform with a RAG chatbot, visual part search and a 3D interior viewer.
view project ↗
BITS x La Marató · BSC Challenge
We won BSC’s Fem visible l’invisible challenge at Bits x La Marató, the charity hackathon supporting La Marató de TV3, using ML to downscale CALIOPE air-quality data across Catalonia.
view project ↗
Datathon FME · AED Challenge
We won first prize among 300 participants. DataMatch used feature matching, PCA, cosine similarity and a chatbot to form compatible hackathon teams.
view project ↗05 / skills.yaml
06 / about.txt
Alongside my studies, I have been exploring robotics and computer vision through research projects, internships and competitions. At IRI, I am developing diffusion policies for path-conditioned quadruped locomotion; before that, I worked on image generation and computer vision at MANGO, and on the perception stack of an autonomous rover for SENER–CEA Bot Talent. I am particularly interested in research around learning, perception and control, and would like to build on that in my Bachelor’s thesis.